Catching robot failures on the line before they happen
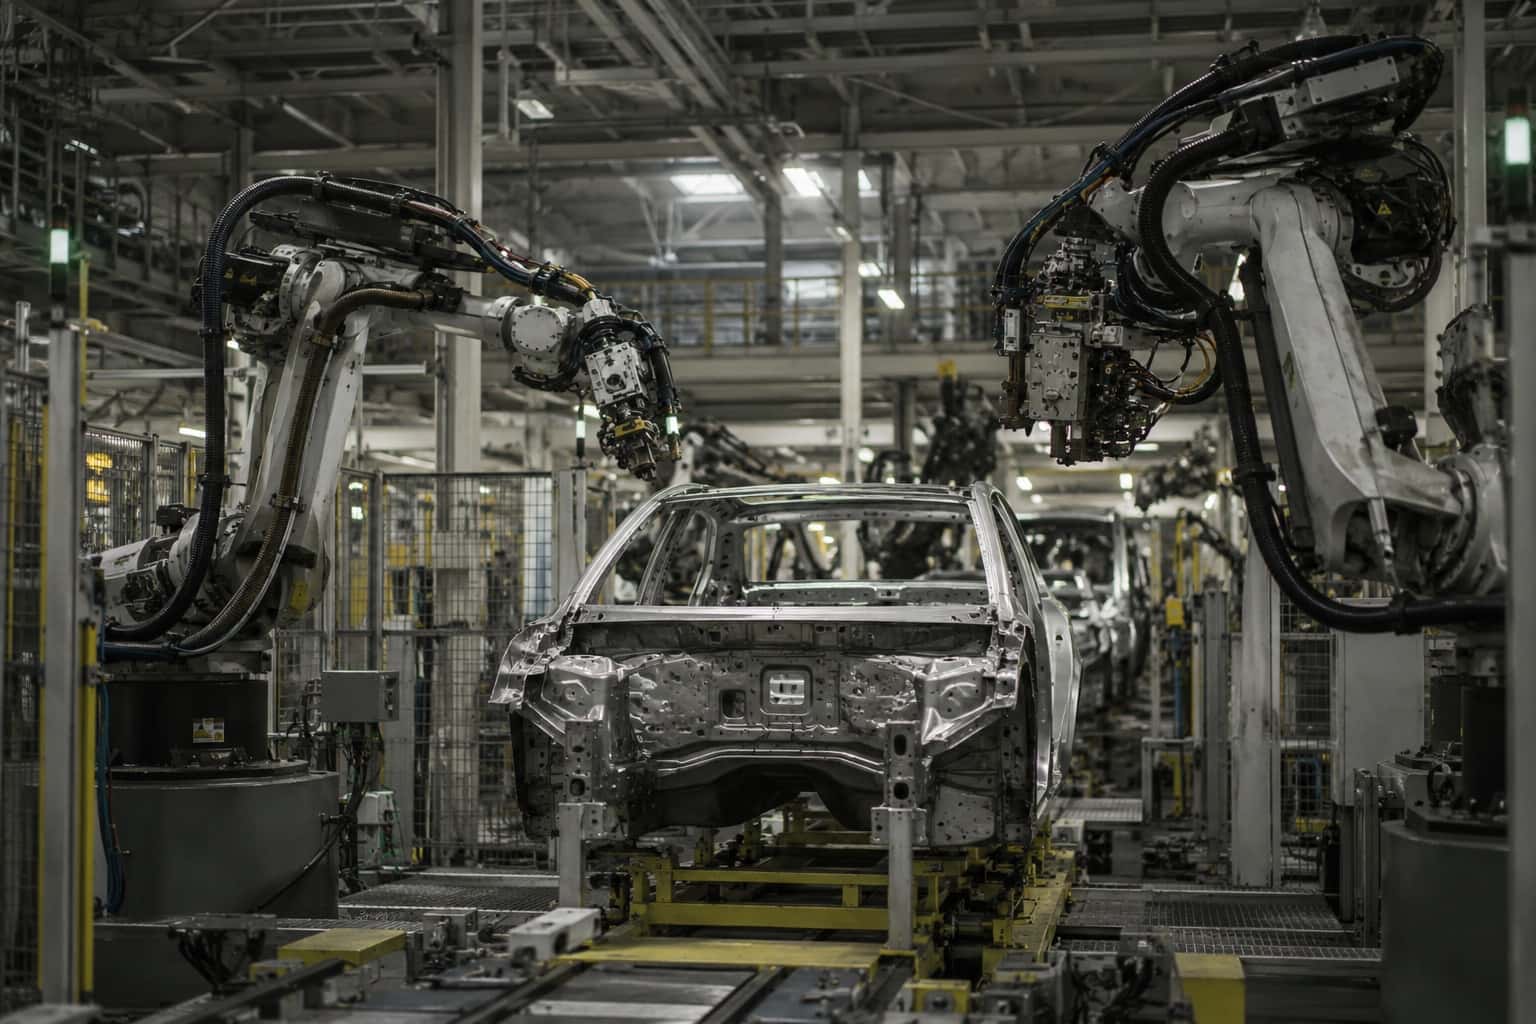
At Datamole AI I built anomaly detection models that predict robot failures in automotive manufacturing. The system reads multivariate sensor data in real time and flags the patterns that come before a failure.
- Role
- Built the anomaly detection models
- Stack
- Python, PyTorch, Kafka, InfluxDB, Docker
>35%
Less unplanned downtime
How it works
- 1
Sensor data
- 2
Signal processing
- 3
Feature extraction
- 4
Anomaly models
supervised and unsupervised
- 5
Alerts
per failure type
- 6
Maintenance view
Results
Unplanned downtime, before and after
Indexed so downtime before the system is 100.
- Before
- After
Unplanned downtime, indexed
Automotive production lines, Datamole AI.
Maintenance teams fixed problems before breakdowns, doing targeted preventive work instead of major repairs.
Key decisions
- 01
Balance false alarms against misses
False alarms send crews to healthy robots and misses let failures through. Thresholds are set per failure type and severity, so each trade-off is made on purpose.
- 02
Clean the signal first
Factory sensor data is noisy and high-dimensional. Careful filtering and time series features that capture early signs of failure came before any model.
- 03
Work across robots and factories
The models had to hold up across robot types, configurations and plants, so they combine statistical methods, deep learning and domain knowledge from industry specialists.
- 04
Output a maintenance team can act on
Alerts say what is likely failing and how urgent it is, so the team can act without a data scientist in the room.